<?xml version="1.0" encoding="UTF-8"?>
<!DOCTYPE X3D PUBLIC "ISO//Web3D//DTD X3D 3.2//EN" "http://www.web3d.org/specifications/x3d-3.2.dtd">
<X3D profile='Immersive' version='3.2'  xmlns:xsd='http://www.w3.org/2001/XMLSchema-instance' xsd:noNamespaceSchemaLocation =' http://www.web3d.org/specifications/x3d-3.2.xsd '>
<head>
<meta name='title' content='SH60Seahawk.x3d'/>
<meta name='creator' content='Michael Collins'/>
<meta name='created' content='10 March 2001'/>
<meta name='modified' content='12 January 2014'/>
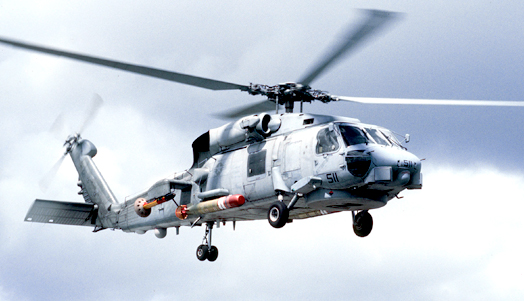
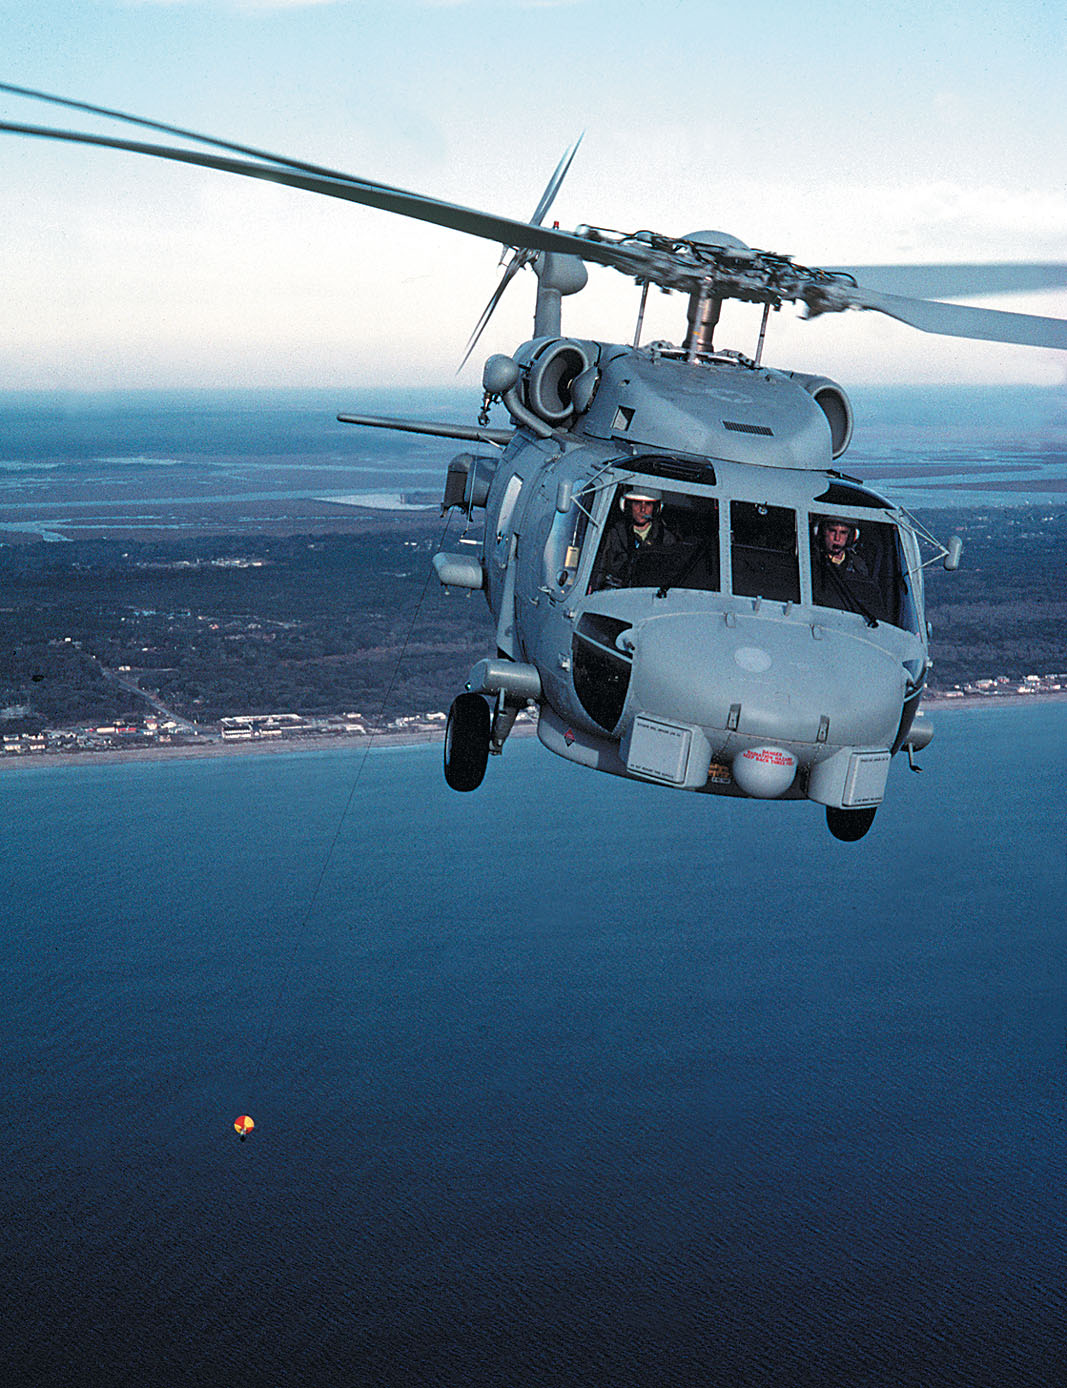
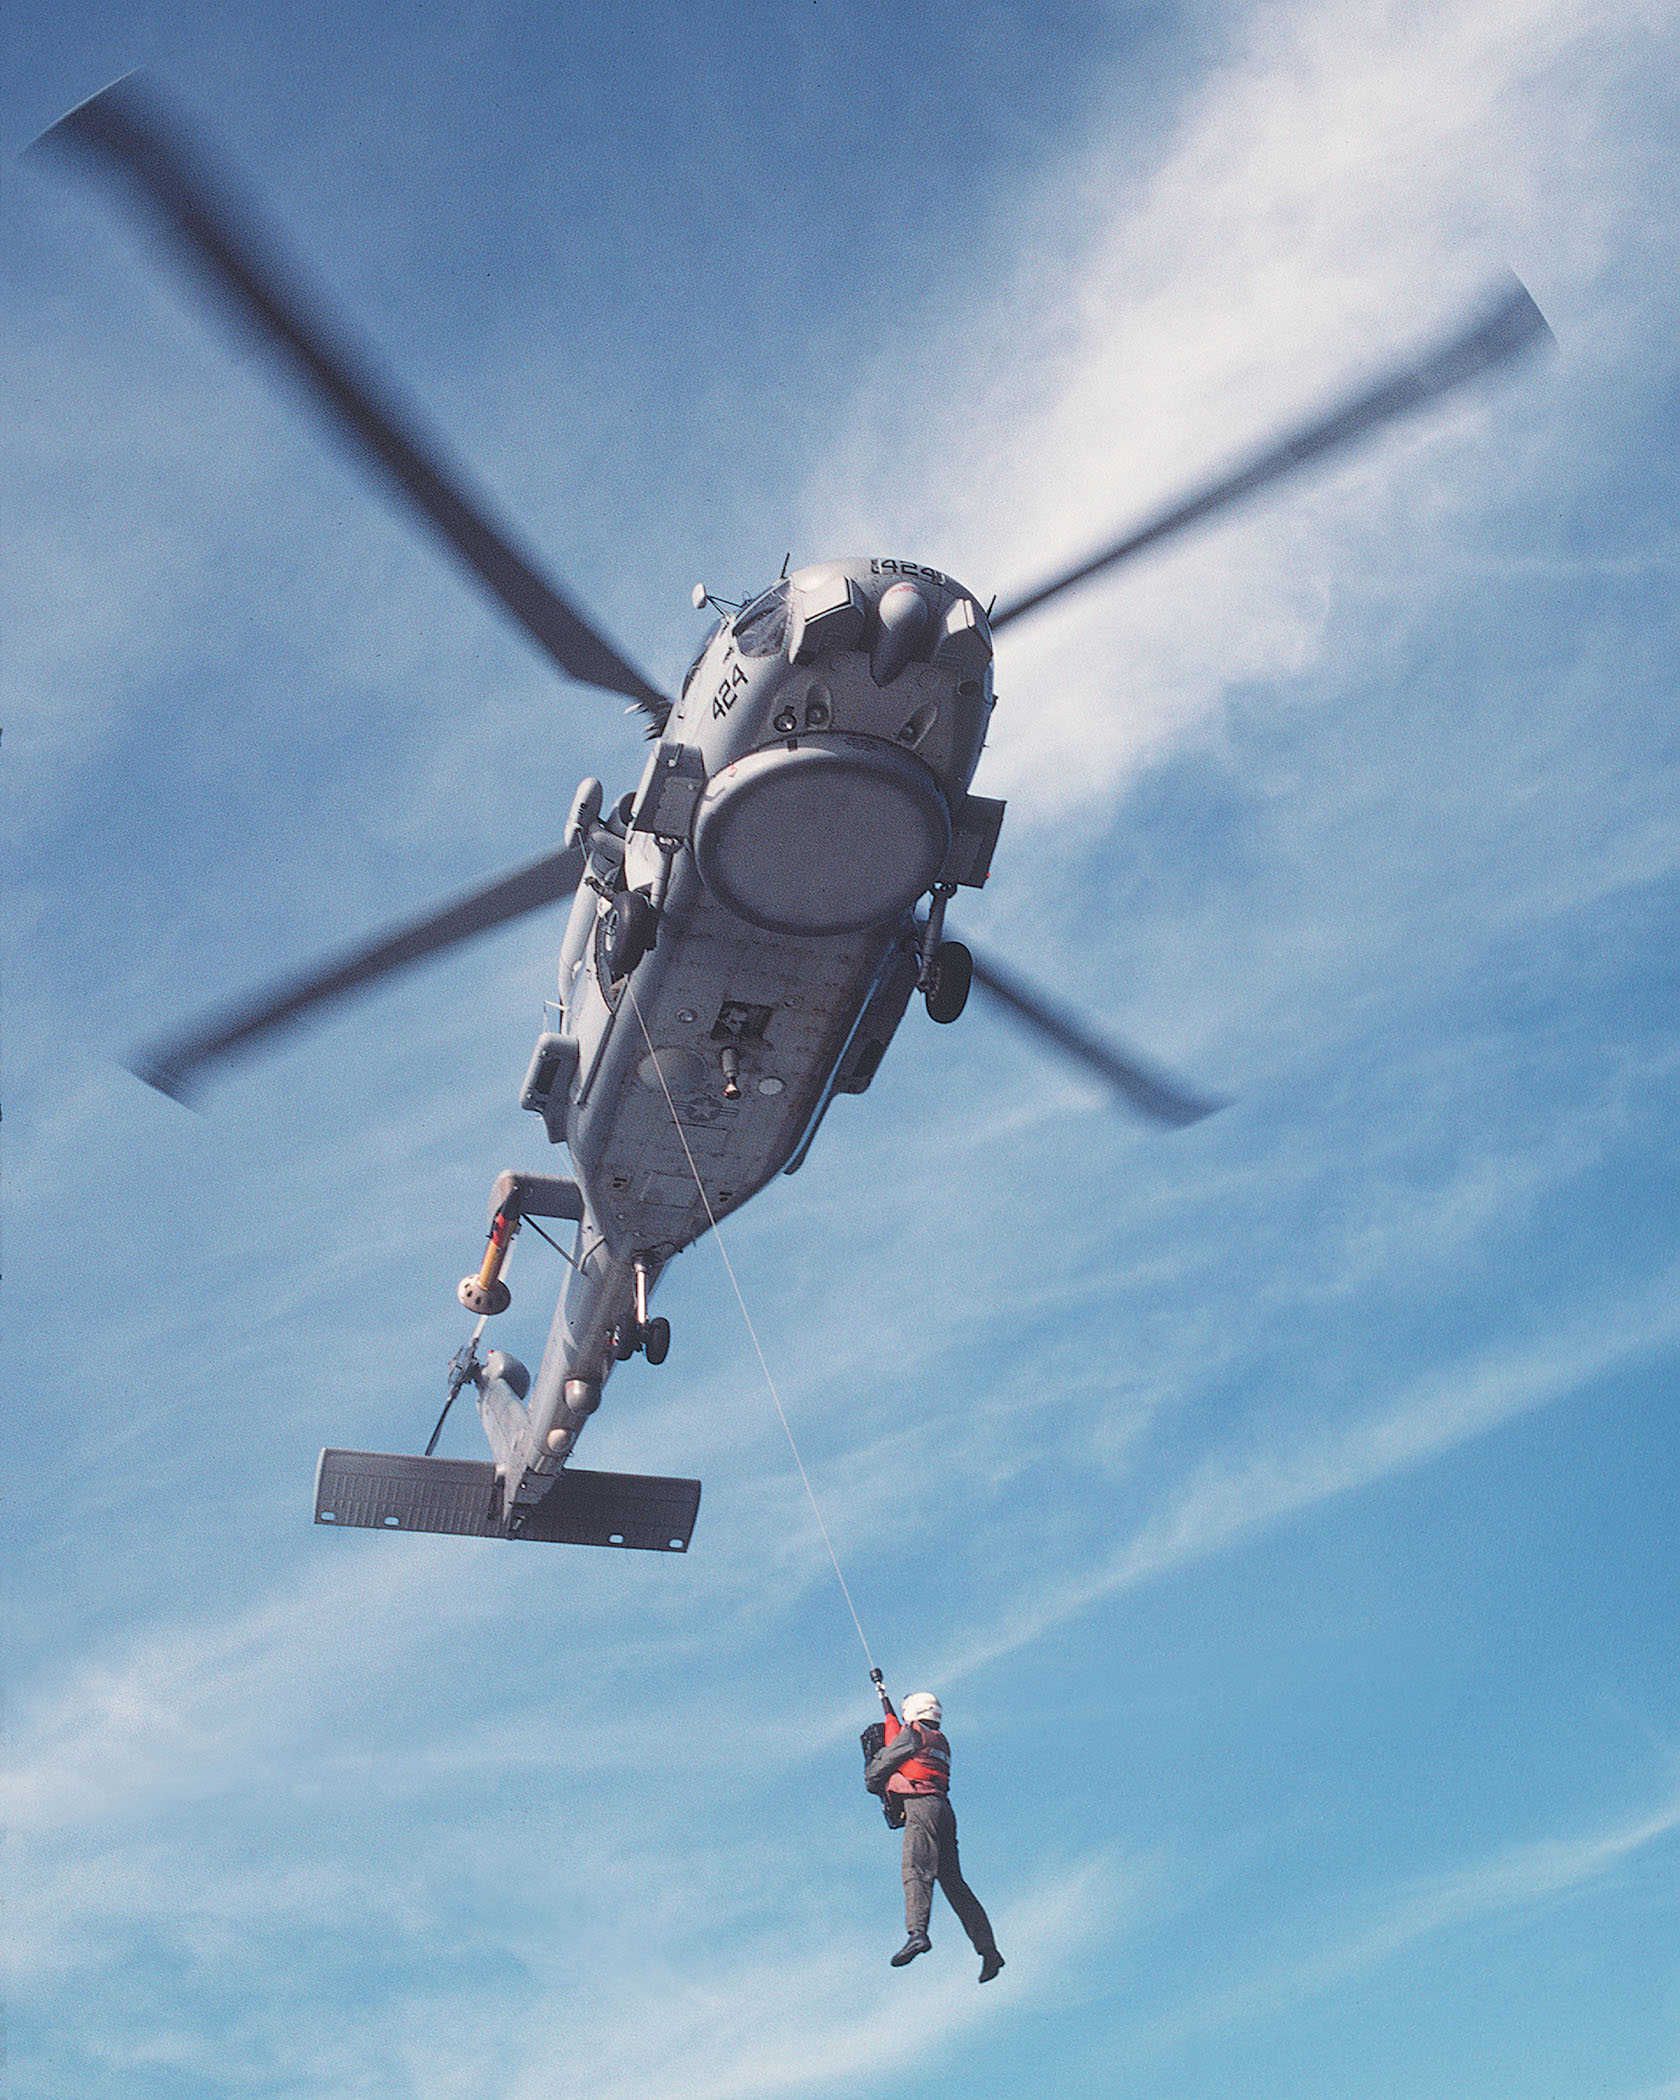
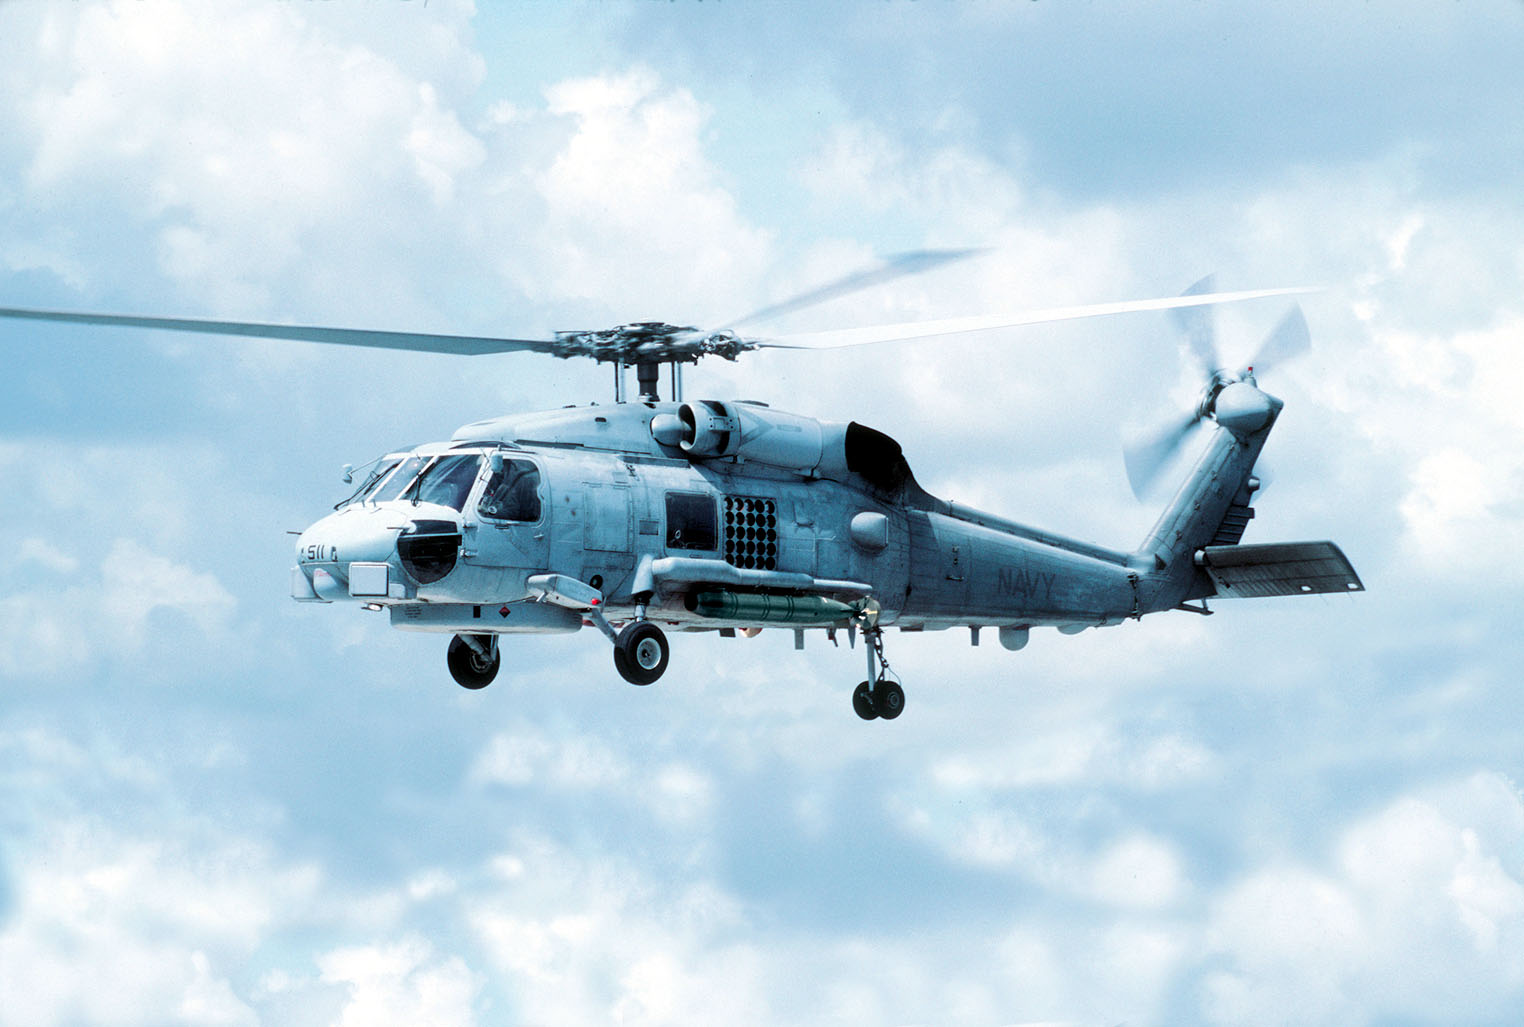
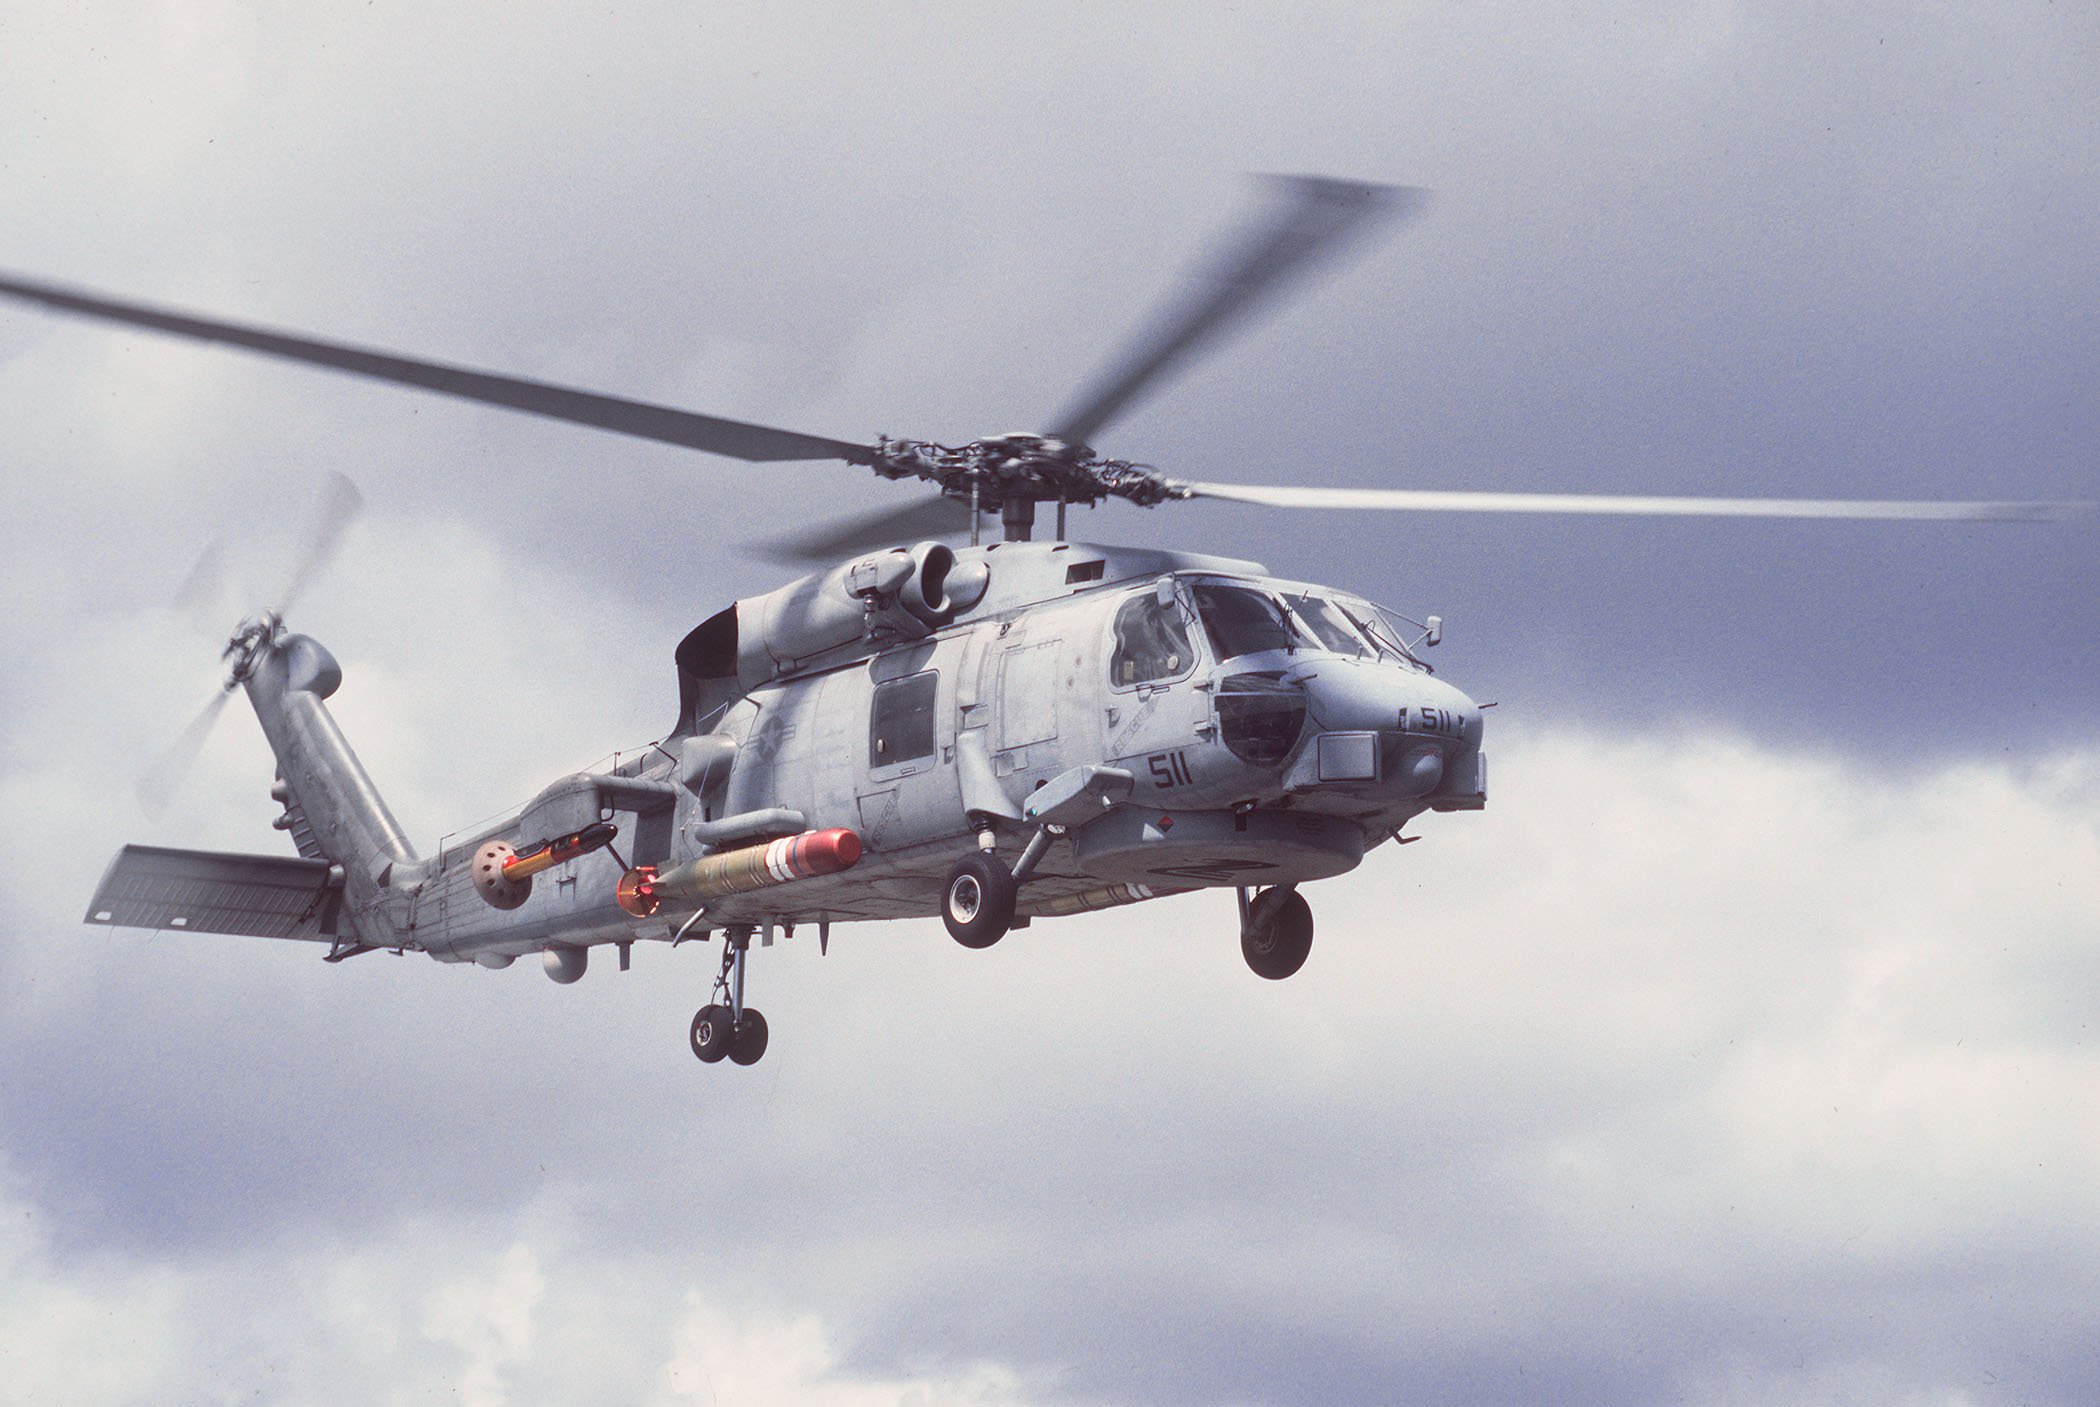
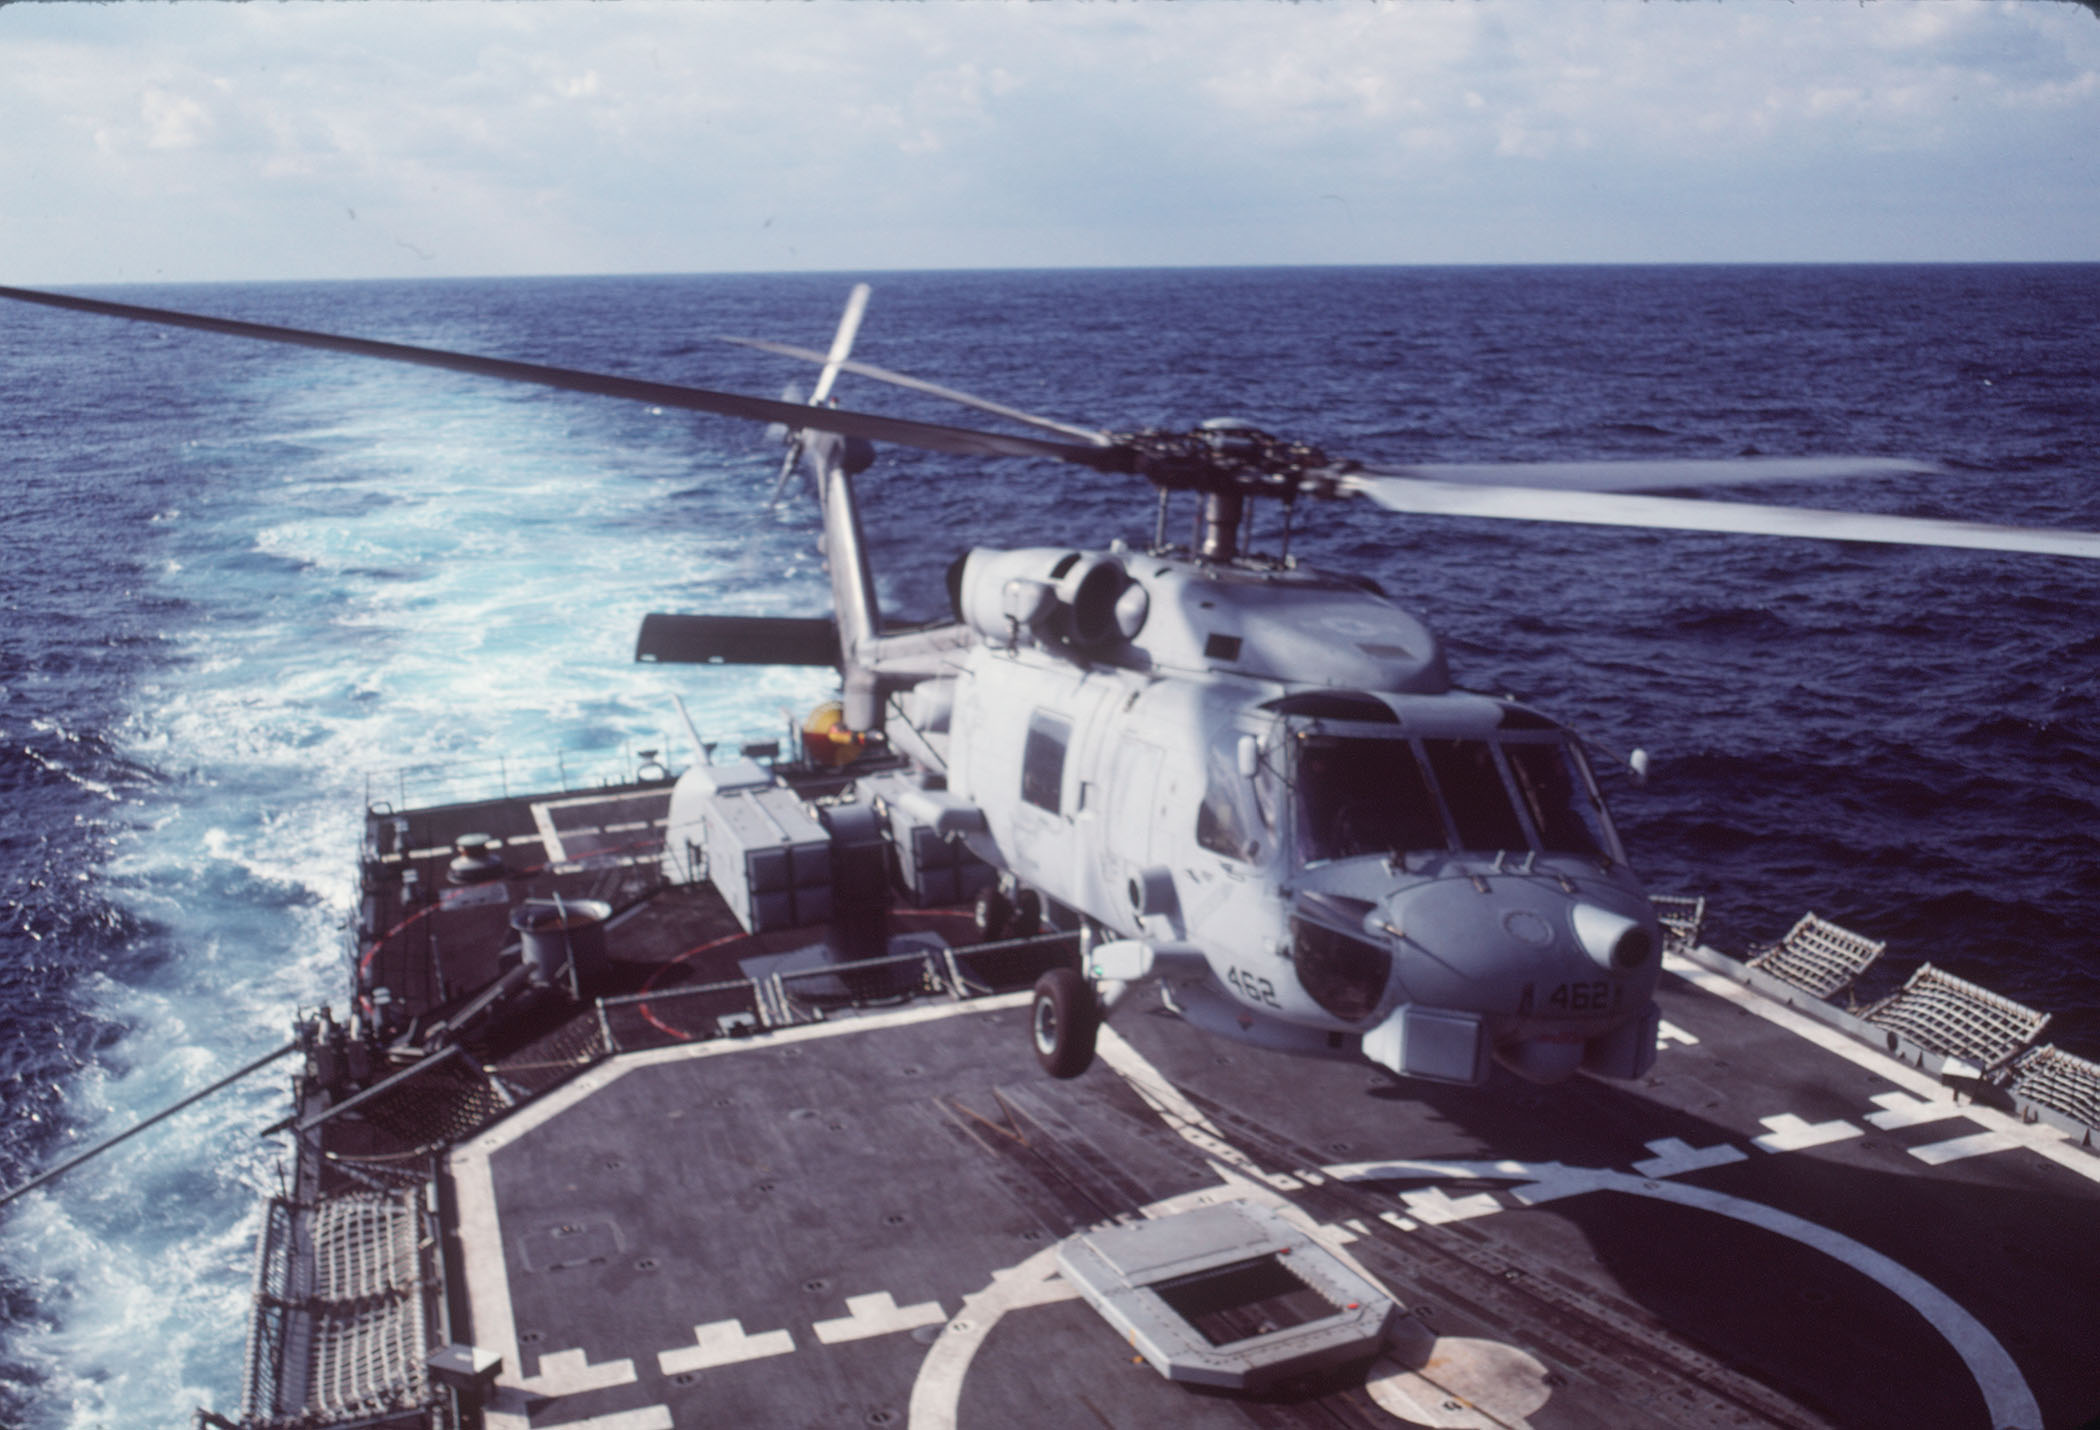
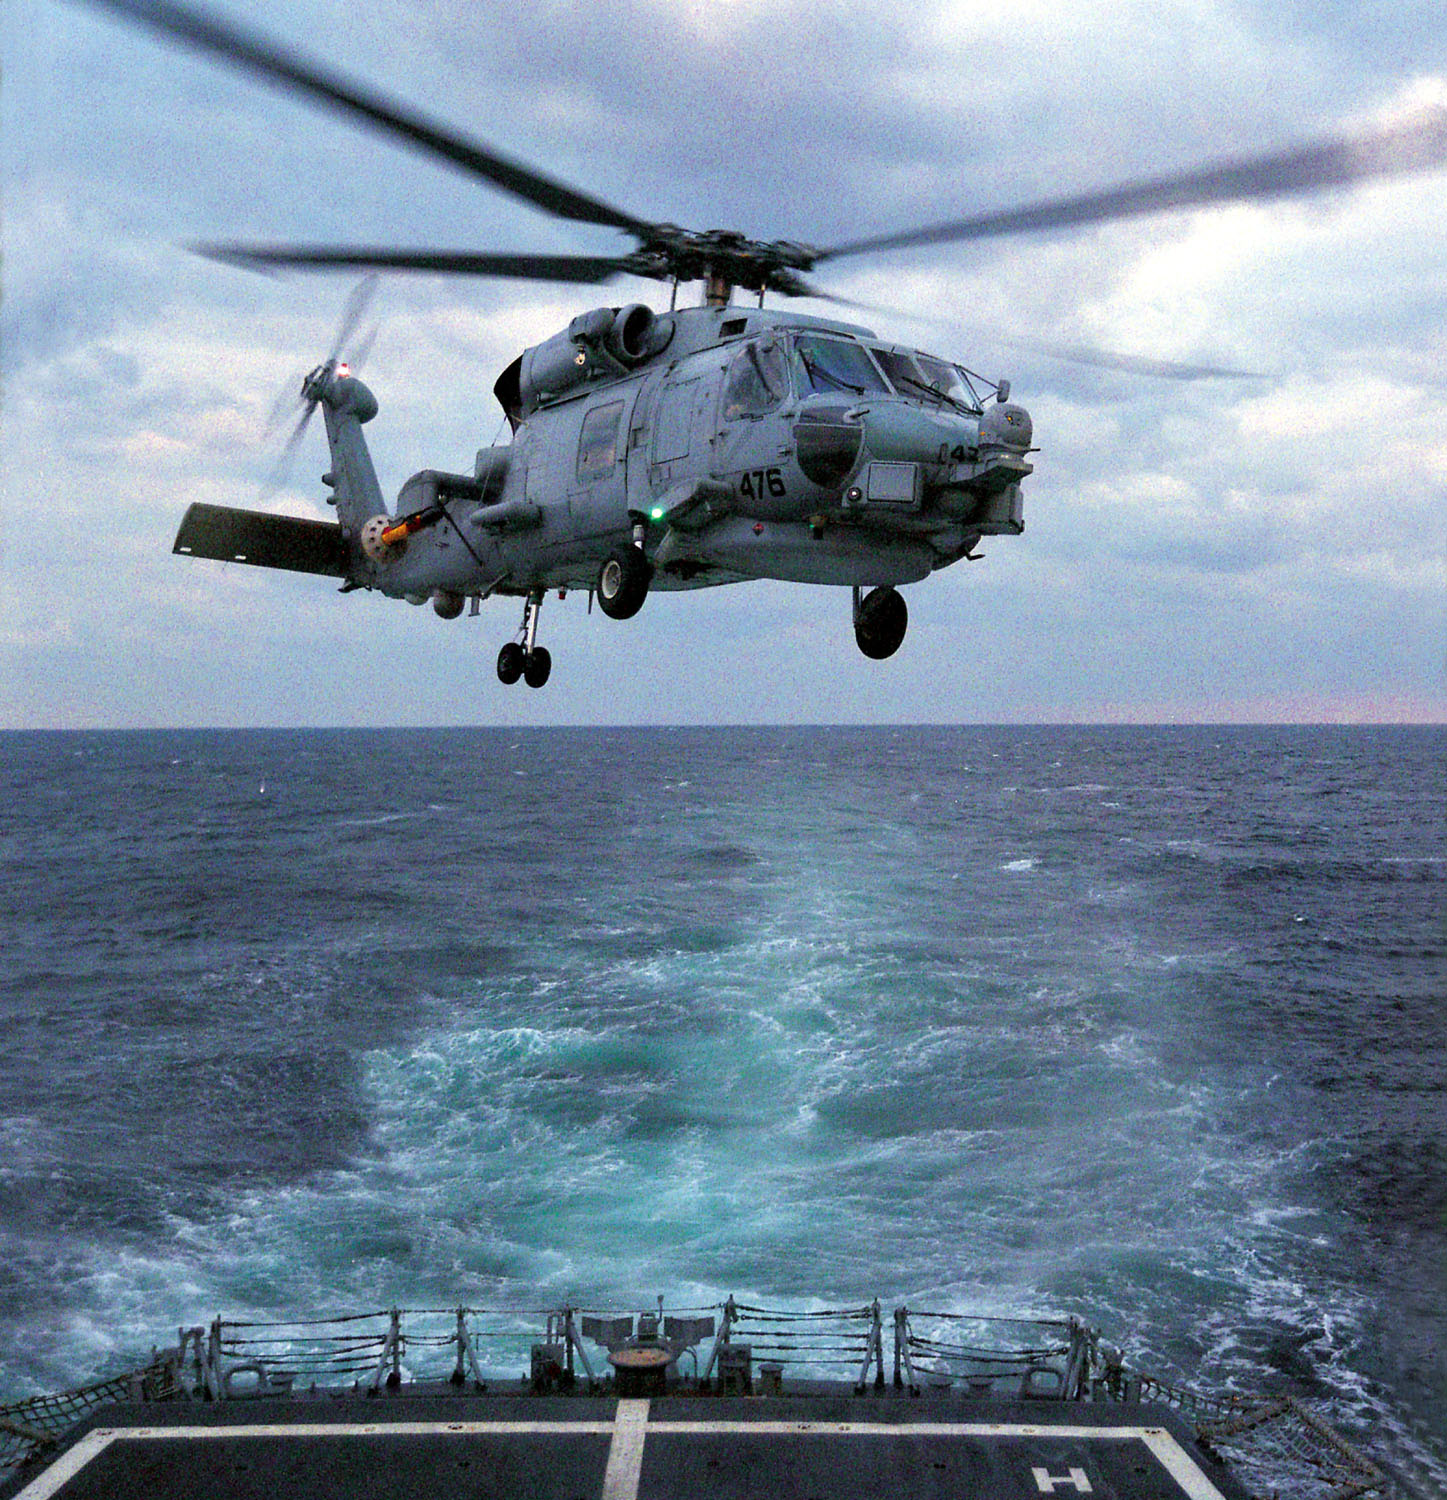
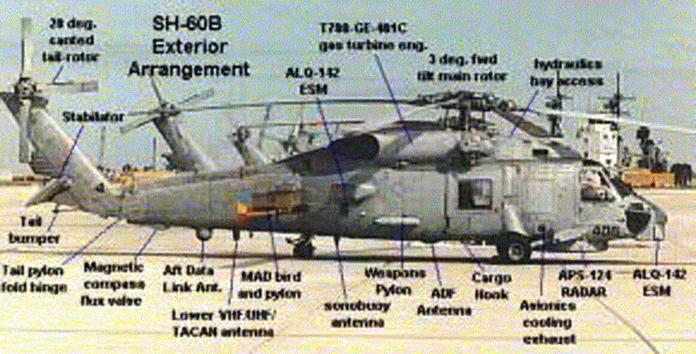
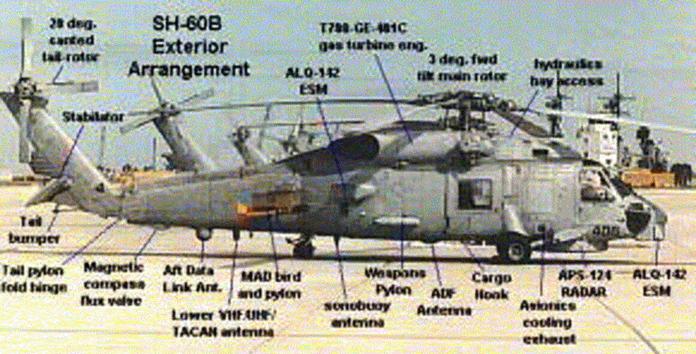
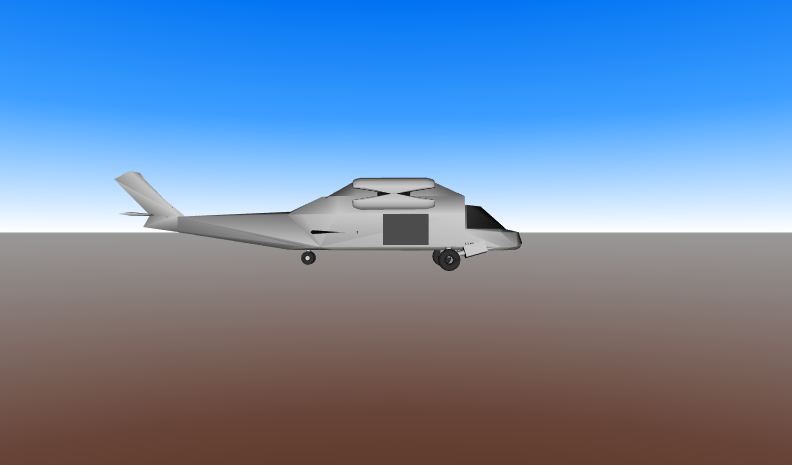
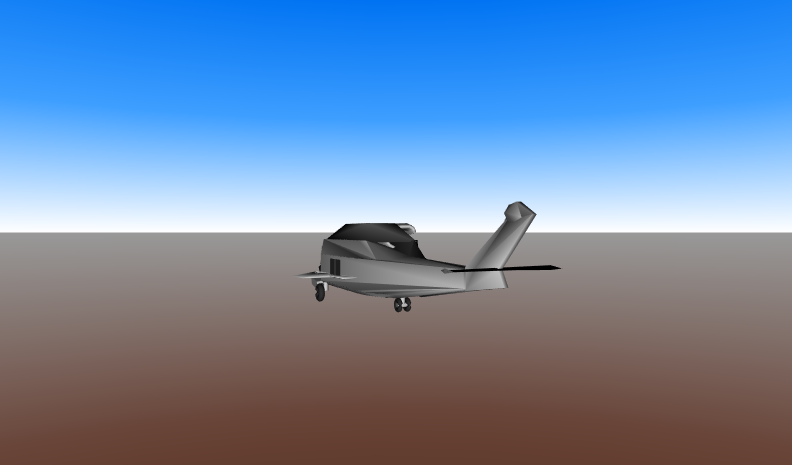
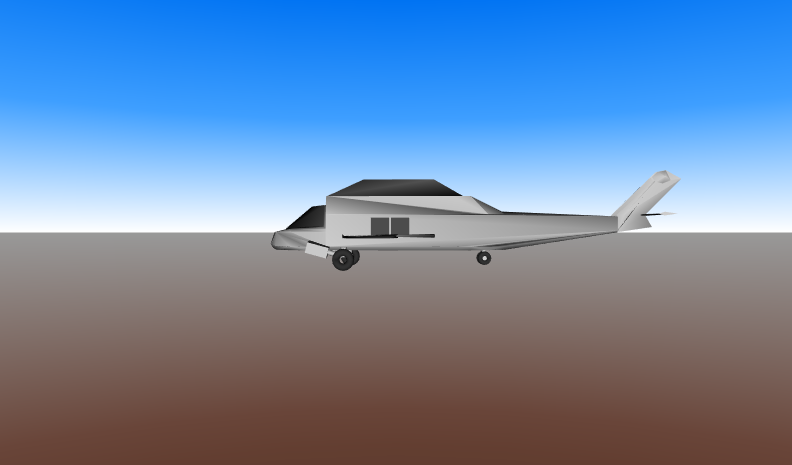
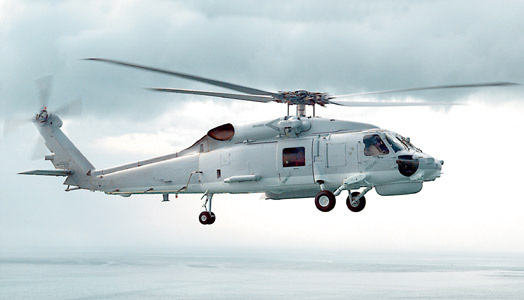
<meta name='description' content='A SH60/HH60 SeaHawk twin-engine helicopter is used for anti-submarine warfare, search and rescue, drug interdiction, anti-ship warfare, cargo lift, and special operations. Created using indexed face sets.'/>
<meta name='identifier' content=' https://savage.nps.edu/Savage/AircraftHelicopters/SH60-Seahawk-UnitedStates/SH60Seahawk.x3d '/>
<!-- images and technical details from Sikorsky web site, 1 February 2003 -->
<meta name='photograph' content='Seahawk_main.jpeg'/>
<meta name='photograph' content='SH60B.jpeg'/>
<meta name='reference' content='SikorskySH60bMissionBrief.pdf'/>
<meta name='reference' content='0,3036,CLI1_DIV69_ETI264,00.pdf'/>
<meta name='reference' content='1,3024,CLI1_DIV69_ETI.pdf'/>
<meta name='photograph' content='SH60B_0001H.jpeg'/>
<meta name='photograph' content='SH60B_0002H.jpeg'/>
<meta name='photograph' content='SH60B_0003H.jpeg'/>
<meta name='photograph' content='SH60B_0004H.jpeg'/>
<meta name='photograph' content='SH60B_0005H.jpeg'/>
<meta name='photograph' content='SH60B_0006H.jpeg'/>
<meta name='reference' content=' http://www.sikorsky.com/details/0,3036,CLI1_DIV69_ETI264,00.html '/>
<meta name='reference' content=' http://www.fas.org/man/dod-101/sys/ac/sh-60.htm '/>
<meta name='Image' content='sh-60-406lg2.jpg'/>
<meta name='Image' content=' http://www.fas.org/man/dod-101/sys/ac/sh-60-406lg2.jpg '/>
<meta name='generator' content='X3D-Edit 3.2, https://savage.nps.edu/X3D-Edit'/>
<meta name='license' content=' ../../license.html'/>
</head>
<!-- -->
<Scene>
<Background groundAngle='1.309 1.570796' groundColor='0.1 0.1 0 0.4 0.25 0.2 0.6 0.6 0.6' skyAngle='1.309 1.571' skyColor='0 0.2 0.7 0 0.5 1 1 1 1'/>
<Group DEF='ViewpointGroup'>
<!-- ViewpointGroup node not yet widely supported -->
<Viewpoint description='Seahawk SH60 helicopter, starboard side'/>
<Viewpoint description='Wide Angle View from SH60 Helicopter' fieldOfView='1.1' orientation='1 0 0 -0.38' position='0 10 20'/>
<Viewpoint description='Seahawk echelon left' orientation='0 1 0 -1.2' position='-10 0.75 4'/>
<Viewpoint description='Seahawk echelon right' orientation='0 1 0 -2' position='-10 0.75 -4'/>
<Viewpoint description='Seahawk port side' orientation='0 1 0 3.14159' position='0 0 -10'/>
<Viewpoint description='Seahawk from ahead' orientation='0 1 0 1.57' position='10 0.75 0'/>
<Viewpoint description='Seahawk from below' orientation='1 0 0 1.57' position='0 -10 0'/>
</Group>
<!-- Original model in feet -->
<ExternProtoDeclare name='ViewPositionOrientation' appinfo='ViewPositionOrientation provides provides console output of local position and orientation as user navigates'
  url=' "../../Tools/Authoring/ViewPositionOrientationPrototype.x3d#ViewPositionOrientation" "https://savage.nps.edu/Savage/Tools/Authoring/ViewPositionOrientationPrototype.x3d#ViewPositionOrientation" "../../Tools/Authoring/ViewPositionOrientationPrototype.wrl#ViewPositionOrientation" "https://savage.nps.edu/Savage/Tools/Authoring/ViewPositionOrientationPrototype.wrl#ViewPositionOrientation" '>
<field name='enabled' type='SFBool' accessType='inputOutput'
 appinfo='Whether or not ViewPositionOrientation sends output to console'/>

<field name='traceEnabled' type='SFBool' accessType='initializeOnly'
 appinfo='Output internal trace messages for debugging this node, intended for developer use only'/>

<field name='set_traceEnabled' type='SFBool' accessType='inputOnly'
 appinfo='Ability to turn output tracing on/off at runtime'/>

<field name='position_changed' type='SFVec3f' accessType='outputOnly'
 appinfo='Output local position'/>

<field name='orientation_changed' type='SFRotation' accessType='outputOnly'
 appinfo='Output local orientation'/>

<field name='outputViewpointString' type='MFString' accessType='outputOnly'
 appinfo='MFString value of new Viewpoint'/>
</ExternProtoDeclare>
<Switch DEF='AuthoringAssist' whichChoice='-1'> </Switch>
<Transform DEF='ScaleCenterAlignNoseWithX-Axis' rotation='0 1 0 3.14159' scale='0.3048 0.3048 0.3048' translation='-4 -0.3 -0.7'>
<Transform translation='-.5 1 -2.4'> </Transform>
<Transform scale='.8 .8 .8' translation='-13 4.8 -2.4'> </Transform>
<Transform rotation='0 1 0 3.12'> </Transform>
<Transform rotation='0 1 0 1.57' scale='.13 .13 .13' translation='-8 -.5 -2.5'> </Transform>
<Transform rotation='0 1 0 -1.57' scale='.2 .2 .2' translation='-16 -.5 0'> </Transform>
<Transform rotation='0 1 0 -1.57' scale='.2 .2 .2' translation='-16 -.5 -4.8'> </Transform>
<Transform rotation='1 0 0 3.2' translation='-13 3 -1'> </Transform>
<Transform rotation='0 0 1 1.57' scale='.45 .45 .45' translation='-13 3.1 -3.5'>
<Inline USE='Engine'/>
</Transform>
<Transform rotation='0 1 0 1.57' scale='1 1 .5' translation='-11 1 -3.8'> </Transform>
<Transform rotation='0 1 0 -1.57' translation='-16 .8 .5'> </Transform>
</Transform>
</Scene>
</X3D>
<!--

Index for ExternProtoDeclare definition : ViewPositionOrientation

Index for DEF nodes : AuthoringAssist, CoordinateAxes, Engine, ScaleCenterAlignNoseWithX-Axis, ViewpointGroup

Index for Viewpoint images : Viewpoint_1, Viewpoint_2, Viewpoint_3, Viewpoint_4, Viewpoint_5, Viewpoint_6, Viewpoint_7
-->

<!-- Color key: <X3dNode DEF='idName' field='value'/> matches <XmlElement DEF='idName' attribute='value'/>
(Light blue background: behavior node) (Grey background: inserted documentation) (Magenta background: X3D extensibility)
    <Prototype name='ProtoName'> <field name='fieldName'/> </Prototype> -->

<!-- Additional help information about X3D scenes: X3D Resources, X3D Scene Authoring Hints and X3D Tooltips -->